Read the room
RPLidar scan · USB camera · wheel encoder ticks
/scan + /image_raw + serialIndependent robotics / Build log 01
REV. 07.26
Octara Robotics is a working archive of autonomous machines, control software, sensor tests, and the lessons between versions.
 LIVE MAP / 01
Autonomy platform / Working prototype
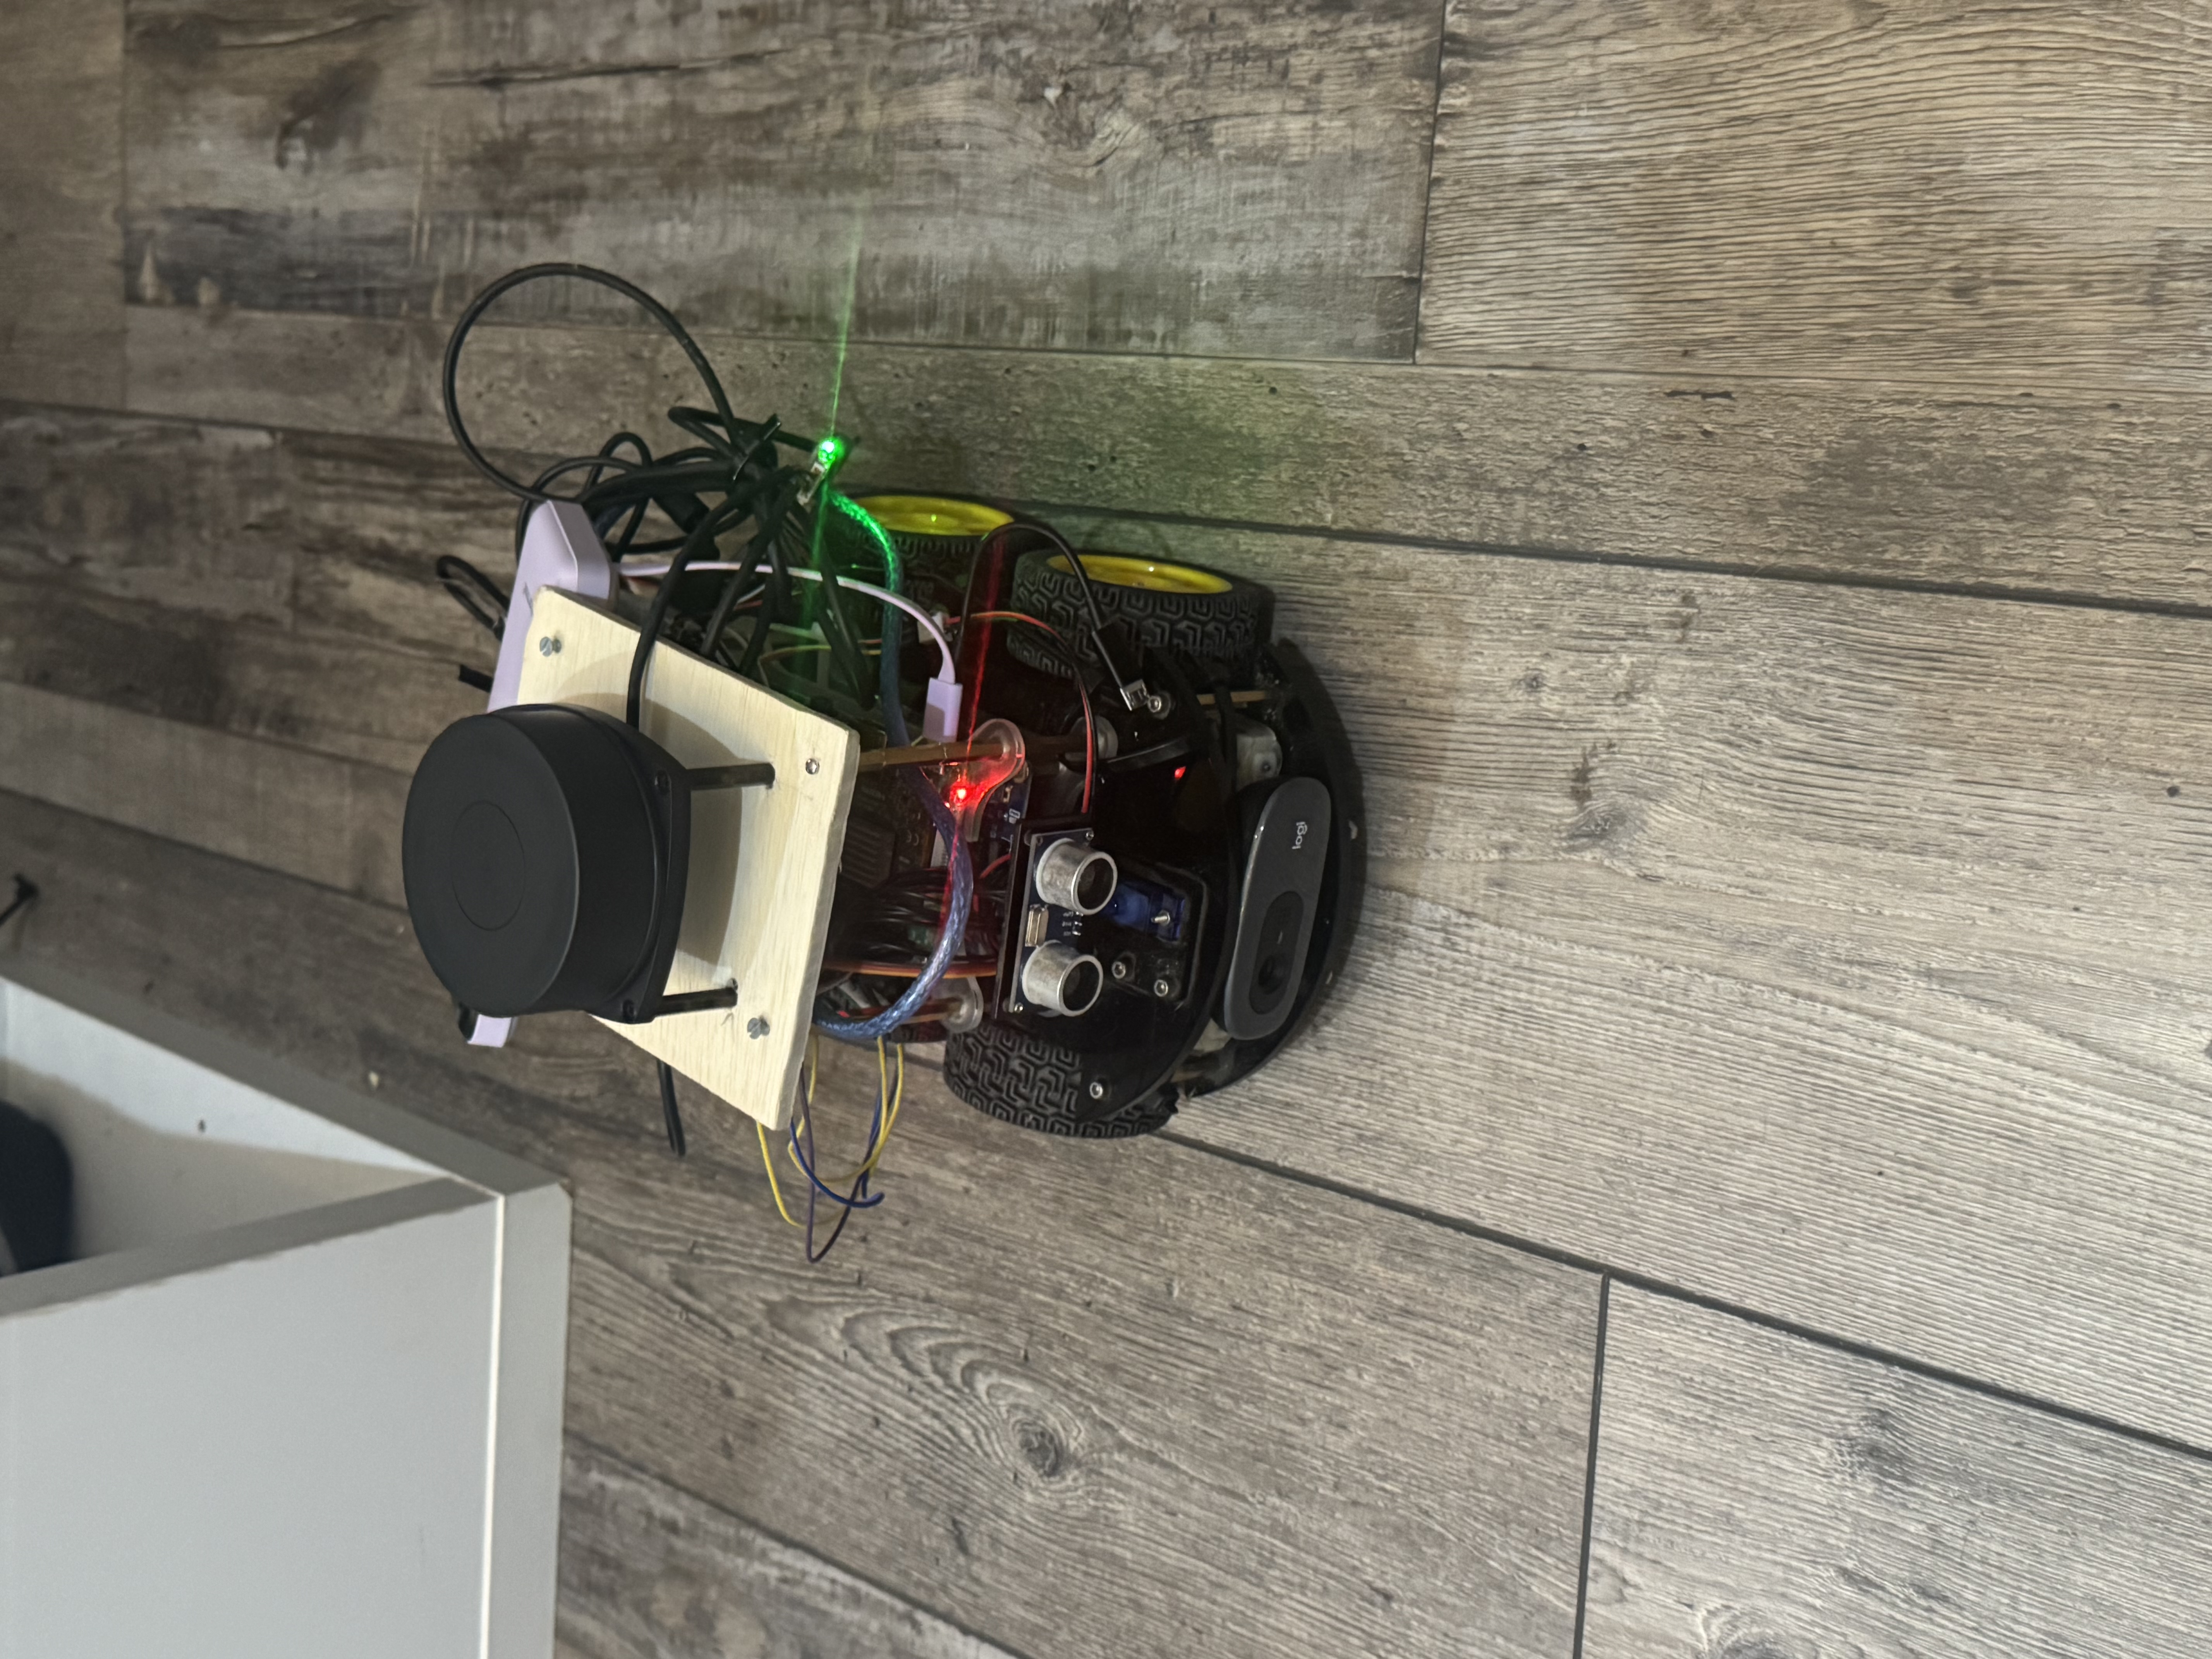
A ROS 2 rover built to map and navigate a home autonomously. Claude combines wheel odometry, LiDAR, a camera, and a carefully staged control stack in one compact platform.
From room to response
Claude turns physical signals into a map, exposes the machine state for inspection, and closes the loop with deliberate motor control.
RPLidar scan · USB camera · wheel encoder ticks
/scan + /image_raw + serialEncoder odometry and tuned SLAM Toolbox parameters
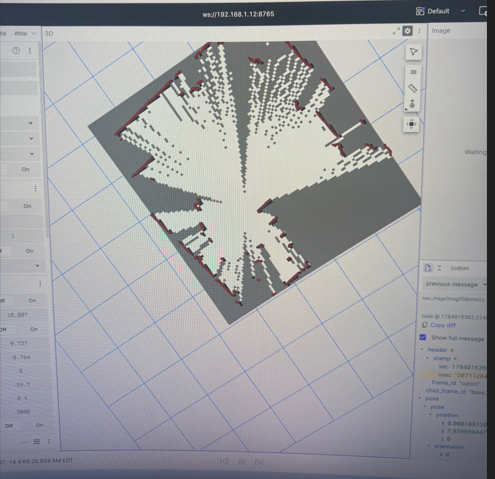
/odom → /mapFoxglove bridge carries mapping and telemetry off-board
ws://rover:8765Safety-gated velocity commands drive the differential base
/cmd_vel → motorsLiDAR returns resolve into walls, openings, and free space as the rover moves through the room.
The robot is a conversation between nodes
Each module has one job, one visible interface, and a status that stays honest about what is working today.
motor_node.pyA clean differential-drive controller that translates ROS velocity commands into physical movement.
webcam_node.pyA USB camera pipeline that publishes both raw and compressed image streams for remote inspection.
safety_node.pyA sonar-gated command relay designed to stop forward motion when an obstacle enters the safety zone.
The interesting part is the iteration
The public build log keeps the sequence visible: define one behavior, prove it on hardware, integrate it into the stack, then test the whole loop again.
A working loop beats a perfect diagram. Prove one signal path, then add the next.
The debugging trail is part of the build. It makes every revision faster and more legible.
Every sensor, node, and abstraction has to make the machine more dependable.
Octara Robotics / Intelligence. Precision. Protection.
Octara is where physical builds, control code, and practical machine intelligence stay visible. The goal is simple: make autonomous systems that understand their environment and earn trust one revision at a time.